Reaching The Pinnacle of the Digital World Open Mathematical Problems in AI-Driven Robot
Abstract
The convergence of Artificial Intelligence (AI) and robotics has brought about a fresh period of autonomous systems able to execute sophisticated jobs in changing and unpredictable settings. Although significant advancements have been achieved, a multitude of unresolved mathematical issues limit the use of AI-driven robots in safety-critical and real-world uses. Focusing on robustness, safety, learning, Human-Robot Interaction (HRI), and complicated system management, this study investigates several significant unresolved concerns at the crossroads of AI, control theory, and mathematics. Creating intelligent, dependable, and trustworthy autonomous robots depends on addressing these obstacles. Several influential open problems are introduced within the folds of this paper, with final thoughts on mathematizing AI-driven robot control.
Keywords:Artificial intelligenceArtificial intelligence-driven robotsMachine learningRoboticsReinforcement
learning, Deep neural networks.
1. Introduction
Advances in Artificial Intelligence (AI), especially machine learning, are propelling a major change in the field of robotics. Mostly grounded in classical control theory, conventional robot control often depends on exact models and controlled surroundings (Such as the convergence of AI), and robotics has produced a new era of autonomous systems capable of performing complex tasks in dynamic and unexpected environments [1]. Although significant innovations have been made, several unsolved mathematical problems restrict the application of AI-driven robots in safety-sensitive and real-world scenarios, as in Fig. 1 [1].
Emphasizing robustness, safety, learning, Human-Robot Interaction (HRI), and sophisticated system management, this research explores multiple critical unanswered questions at the intersection of AI, control theory, and mathematics [1]. Building very intelligent, reliable, and trustworthy autonomous robots depends on overcoming these challenges [2]. But actual situations are naturally complicated, unpredictable, and dynamic, requiring more clever and flexible control systems. With its capacity to learn from data [1], detect sophisticated patterns, and make decisions under ambiguity, AI provides a great toolbox for tackling these problems.
Broad range of approaches including Reinforcement Learning (RL) [3], [4], deep learning for perception and decision-making [5], imitation learning, and various forms of adaptive control define AI-driven robot control. From negotiating unsorted surfaces to executing complex manipulating tasks [6], these approaches have allowed robots to accomplish amazing tasks.
Still, the change from managed laboratory environments to large-scale actual application exposes basic theoretical and mathematical deficiencies [6]. This document seeks to outline some of these important unresolved issues, therefore emphasizing places where strict mathematical structures are required to guarantee the robustness [6], safety, and generalizability of AI-driven robotic systems.
2. Safety Guarantees and Robustness
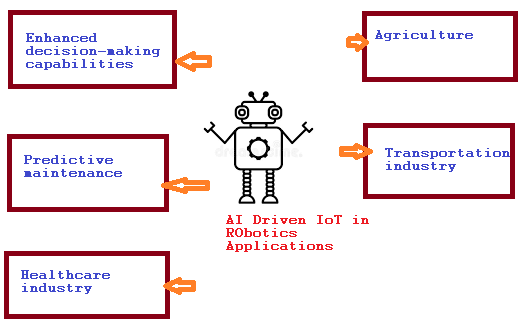
For AI-driven robots, particularly in safety-critical settings (e.g., autonomous driving, surgical robots), the absence of official assurances about their reliability and safety is one of their most important issues, as depicted in Fig.2 [7].
2.1 Official Verification of Neural Network Controllers
Deep Neural Networks (DNNs), used for perception, policy learning, or state estimation, abound in many contemporary AI-driven robot control systems. Being very opaque “Black boxes,” DNNs complicate greatly the formal verification of their behavior [8].
Problem: How can we mathematically prove that a neural network controller will always operate within specified safety boundaries, avoid collisions, or maintain stability under all permissible inputs and environmental conditions [9]?
Challenges: Conventional formal verification techniques are impractical given the non-linear, high-dimensional character of DNNs and their sensitivity to hostile attacks [10]. New mathematical methods are required to examine reachable sets of DNN-controlled systems, check Lipschitz continuity features, and formulate probabilistic safety promises [10]. The DNN-controlled system entails creating strong techniques for measuring uncertainty flow across neural networks and incorporating them into Control Lyapunov Functions (CLFs) or Control Barrier Functions (CBFs) [10], [11].
2.2 Uncertainty Propagation and Quantification
Sensor noise, model errors, unexpected disturbances, and limited knowledge all contribute to the inherent uncertainty of real-world situations. Reliable operation is required for AI-driven robots despite this variability [12], [13].
Problem: How can we accurately quantify and propagate uncertainties through complex AI models and control loops [14], ensuring that decision-making accounts for these uncertainties in a principled manner? Bayesian approaches present an intriguing path, but their computational difficulty is their scaling to high-dimensional robot states [15] and deep learning models. Still, an open area is developing tractable solutions for probabilistic inference [16], resilient state estimation (e.g., robust Kalman filters, particle filters for non-Gaussian uncertainties), and decision-making under extreme uncertainty (e.g., using robust optimization or minimax control). An open area covers mathematically, defining how downstream control activities are affected by perception inaccuracies [16].
2.3 Oppositional Robustness
Particularly deep learning models [17], AI systems are susceptible to adversarial attacks, in which case tiny, barely noticeable changes to inputs might produce very erroneous results. For robots, this might show up as misreading instructions, misidentifying things, or sensing phantom barriers [18].
Problem: How can we build AI-driven robot control systems that are certainly robust against adversarial perturbations in their sensor inputs or internal states [18]?
Challenges: Modern adversarial training approaches might produce few assurances and could lower performance on clean data [19]. Understanding the geometry of adversarial instances in high-dimensional state spaces, creating certified robustness solutions for robotic applications, and designing control laws that are automatically resistant to such assaults require novel mathematical frameworks [20]. A novel mathematical framework investigates relations between control theory, game theory, and adversarial machine learning [21].
3. Adaptation and Learning
Although AI's strength is in its learning, current learning paradigms for robot control confront major mathematical challenges regarding efficiency, generalization, and continuous adaptation.
3.1 Reinforcement Learning Sample Efficiency
Although RL, has had outstanding performance in simulated environments, its use on actual robots is sometimes hindered by great sample inefficiency [3], [4]. Training, a robot in the actual world is expensive, labor-intensive, and possibly dangerous [3], [4].
Problem: How can we create mathematically grounded RL systems that learn optimal or near-optimal control policies with much less real-world contact [22]?
Challenges: This covers research into model-based RL (Learning dynamics models), off-policy learning, transfer learning from simulation to reality (Sim-to-real), and efficient exploration strategies [23]. Mathematically means improving knowledge of the circumstances for successful policy transfer, developing tighter bounds on sample complexity [24], and creating best experimental design plans for robot learning. Active research fields include Bayesian optimization, meta-learning, and information-theoretic approaches to exploration.
3.2 Lifelong and Continuous Learning
Robots used in the real world need to constantly change to new circumstances, dynamic surroundings, and fresh jobs without forgetting earlier acquired abilities (Catastrophic forgetting) [25].
Problem: How can we mathematically model and solve the issue of lifelong learning for robot control [26], therefore allowing continuous adaptation and skill acquisition without performance drop on past tasks? Challenges: This calls for fresh mathematical models for knowledge representation, memory management [27], and transfer learning with incremental policy and model updating. Relevant are methods from biologically inspired neural architectures, concept drift adaptation [28], and online learning. It is essential to create metrics and theoretical guarantees for measuring and guaranteeing good transfer and to minimize catastrophic forgetting in robotic applications [29].
3.3 Generalization and Out-of-Distribution Robustness
One of the main drawbacks of modern AI systems is their weak generalization to data or circumstances much different from their training distribution (Out-of-Distribution (OOD)) [8]. For robots, this means that a policy developed in one context might perform horrifically in another rather similar environment [30]. Problem: How can we mathematically characterize and enhance the generalization abilities of AI-driven robot controllers to fresh [30], unfamiliar settings and duties?
Challenges: This calls for a deeper knowledge of the inductive biases of learning algorithms [31], the intrinsic dimensionality of robotic tasks, and the creation of domain adaption methods with robust theoretical guarantees. Mathematical bases for developing more generalizable robot behaviors can be found in causal inference, invariant learning, and robust optimization [32].
4. Human–Robot Interaction
Complex mathematical models are required to comprehend human intent [33], guarantee safe cooperation, and build trust so that robots may be smoothly and safely integrated into human surroundings.
4.1 Intent Prediction and Inference
Robots must correctly infer and project human intentions [34], goals, and future actions for efficient teamwork.
Problem: How can we enable proactive and cooperative robot behavior by means of strong mathematical models for real-time human intent inference [34], particularly in uncertain or partially visible situations? Challenges: Major mathematical problems are quantifying the uncertainty in intent predictions and creating control policies resistant to misinterpretations [34]. This also covers knowledge of cognitive states and human tastes [34].
4.2 Shared Autonomy and Variable Autonomy
Many HRI situations include shared control between the person and the robot [35], or the degree of robot autonomy changes depending on context.
Problem: How can we mathematically devise optimal control strategies for shared autonomy systems, guaranteeing safety [36], efficiency, and user satisfaction that flawlessly mix human input with robot autonomy?
Challenges: In this include human factors, optimal control, and dynamic system modeling. Mathematical models are required for human trust, cognitive load, and error propagation in shared control loops [18]. This also entails creating arbitration systems and hand-over procedures with official assurances [37].
4.3 Robot Decisions Can Have Ethical Ramifications as They Become More Autonomous
Of first importance is guaranteeing honesty [38], responsibility, and fairness in robot behavior.
Problem: Directly into the mathematical formulation of robot control objectives and learning algorithms [38], how can we embed ethical principles and fairness limitations?
Challenges: This is a developing but essential field. It entails transforming abstract ethical ideas into measurable mathematical limits (e.g., ensuring non-discrimination, minimizing harm, maximizing societal benefit) [39]. Mathematical limits may include constrained optimization, multi-objective optimization, and the integration of social welfare functions into control design [39].
5. Regulation of Complex Robotic Systems
Managing big, varied, or very dynamic robotic systems presents special mathematical difficulties.
5.1 Decentralized Control and Multi-Robot Coordination
Often in a dispersed way without a centralized coordinator [40], many real-world projects involve teams of robots working together to meet shared objectives.
Problem: How can we create scalable and strong mathematical frameworks for decentralized control and coordination of big multi-robot systems [40], therefore guaranteeing emergent desirable behaviours and preventing undesirable ones?
Challenges: In this include swarm intelligence, graph theory, game theory, and distributed optimization [41]. A major mathematical difficulty is guaranteeing stability, convergence, and fault tolerance in decentralized learning and control techniques [42]. This also covers constrained control, task delegation, and resource distribution among communications [43].
5.2 Hybrid Systems and Event-Triggered Control
Many robotic systems have hybrid dynamics, that is, a mix of continuous physical movement and discrete logical transitions (e.g., switching between modes, contact events) [44].
Problem: Especially when AI components control the discrete transitions [45], how can we create mathematically precise techniques for designing and validating controllers for hybrid robotic systems? Challenges: This calls for formal methods, discrete event systems [46], and continuous control theory. Key mathematical issues are guaranteeing Zeno behavior avoidance [45], stability across mode changes, and robustness to uncertainties in event detection. Event-triggered control [47] where control updates occur only when needed provides efficiency but complicates stability analysis.
5.3 Soft Robots and Deformable Bodies
Soft robots' innate compliance and infinite-dimensional state spaces call into question conventional rigid-body control approaches.
Problem: Particularly when AI is used to learn their intricate, non-linear dynamics [47], how can we create mathematical models and control techniques for very deformable soft robots?
Challenges: This combines continuum mechanics, functional analysis, and innovative techniques for state estimation and control of high-dimensional [48], non-linear systems. Significant mathematical difficulties arise in learning correct forward and inverse models for soft robots and developing controllers able to use their compliance for safe interaction.
6. State Estimating and Perception
Robot control is built on accurate state estimation [49] and perception; AI has transformed these fields, but open mathematical challenges still exist.
6.1 Strong Semantic Perception and Sensor Fusion
To create a complete picture of their surroundings [50], robots use several sensors (Cameras, LiDAR, IMUs). AI-driven perception systems can extract high-level semantic information.
Problem: How can we mathematically fuse heterogeneous sensor data, including semantic information, in a robust and computationally efficient manner to provide accurate and reliable state estimates for control [51]? Problems: This entails robust estimation approaches, deep learning for feature extraction, and probabilistic graphical models. An open field is quantifying the uncertainty in semantic labels and integrating it into state estimation frameworks (e.g., semantic SLAM) [52]. Equally important is strong handling of sensor malfunctions, occlusions, and new objects.
6.2 State Estimation with Limited Observability
Many robotic jobs require dealing with limited knowledge [53] regarding the surroundings or the robot's condition.
Question: How can we create mathematically correct techniques for optimal state estimation and control under high partial observability, especially when AI models are applied to predict missing data [53]?
Challenges: This entails Partially Observable Markov Decision Processes (POMDPs), but realistically robot applications would find scaling them impractical [54]. There are needed approximate inference techniques, active perception strategies, and information-theoretical approaches to sensing [55].
7. Clarification and Interpretability
Many AI models applied in robot control have a "Black-box" quality that hinders trust and debugging [56].
7.1 Control through Interpretable and Explainable Artificial Intelligence
For debugging, certification, and human supervision, knowing why an AI-driven robot makes a specific choice is essential [57].
Problem: How can we create mathematical models to ensure that human operators can understand and explain the decision-making processes of AI-driven robot controllers [58]?
Challenges: This goes beyond just picturing neural network activations. It entails creating techniques to draw human-understandable rules or explanations from intricate policies [59], attribute control actions to certain inputs, and measure the "Reasonableness" of a robot's behavior. Intricate policies may entail symbolic AI integration, counterfactual explanations, or saliency maps [11].
8. Real-Time Limitations and Computational Efficiency
Most robotic applications demand real-time operation, whereas some sophisticated AI techniques are computationally demanding [60].
8.1 Resource-Constrained Artificial Intelligence for Edge Robotics
A major difficulty is deploying sophisticated AI models on limited robot hardware (e.g., limited CPU, GPU, memory, power) [61].
Problem: While maintaining performance and safety guarantees, how can we create mathematically optimal techniques for compressing, quantizing, and optimizing AI models for effective run on edge robotic systems [32]?
Challenges include hardware-aware co-design, efficient architectures (e.g., MobileNets), quantization, and neural network pruning [62]. Important establishing theoretical limits on the performance loss caused by model compression and guaranteeing real-time performance.
8.2 Real-Time Control and Optimization
Many control challenges entail real-time, under tight deadlines, resolution of sophisticated optimization issues [63].
Problem: Often with AI-driven parts, how can we create mathematically efficient algorithms for real-time optimal control and motion planning capable of handling high-dimensional state spaces and non-linear dynamics [64]?
Challenges: This calls for progress in approximate dynamic programming, Model Predictive Control (MPC), and numerical optimization [65]. Active areas include utilizing AI for warm-starting optimization issues [66], developing effective solvers, or directly learning control policies satisfying real-time limitations.
9. Conclusion
An interesting frontier with great possibilities to transform many sectors and facets of daily life is the incorporation of AI into robotic control systems. Unlocking this capability entirely, however, calls for solving a host of fundamental mathematical unsolved issues. From guaranteeing the demonstrable safety and dependability of neural network controllers to allowing robots to learn effectively, generalize well, and interact naturally with people, every obstacle calls for innovative mathematical understanding and serious theoretical frameworks.
An interdisciplinary study at the interface of control theory, machine learning, optimization, formal methods, and applied mathematics should reveal answers to these issues. Improvement in these fields not only enhances the capacities of individual robots but also clears the path for the development of intelligent, dependable, and trustworthy autonomous systems capable of safely and efficiently navigating complicated, erratic, and human-centric surroundings. Fundamentally, a mathematical one, the road to completely autonomous and intelligent robots calls for continuous work and invention to close the current theoretical gaps.
Funding
This research emerged from a radical reimagining of urban futures, fueled entirely by intellectual curiosity and a defiance of conventional funding paradigms. No grants, no sponsors—just pure, unadulterated innovation.
Conflicts of Interest
The authors proudly declare a conflict of interest with the status quo. We reject outdated urban models, bureaucratic inertia, and techno-skepticism. Our allegiance lies solely with disruptive ideas and the untapped potential of smart cities. Consider this a manifesto against mediocrity.
Figures
References
- [1] Kim, S. W., Kong, J. H., Lee, S. W., & Lee, S. (2022). Recent advances of artificial intelligence in manufacturing industrial sectors: A review. International journal of precision engineering and manufacturing, 23(1), 111–129. https://doi.org/10.1007/s12541-021-00600-3
- [2] Cantucci, F., Marini, M., & Falcone, R. (2025). Trustworthiness assessment of an adaptive and explainable robot in a real environment. International journal of social robotics, 1–12. https://doi.org/10.1007/s12369-025-01257-y
- [3] Beck, J., Vuorio, R., Liu, E. Z., Xiong, Z., Zintgraf, L., Finn, C., & Whiteson, S. (2025). A tutorial on meta-reinforcement learning. Foundations and trends® in machine learning, 18(2–3), 224–384. http://dx.doi.org/10.1561/2200000080
- [4] Jensen, K. T. (2023). An introduction to reinforcement learning for neuroscience. https://doi.org/10.48550/arXiv.2311.07315
- [5] Aljamal, M., Patel, S., & Mahmood, A. (2025). Comprehensive review of robotics operating system-based reinforcement learning in robotics. Applied sciences, 15(4), 1–39. https://doi.org/10.3390/app15041840
- [6] Manikandan, S., Kaviya, R. S., Shreeharan, D. H., Subbaiya, R., Vickram, S., Karmegam, N., … ., & Govarthanan, M. (2025). Artificial intelligence‐driven sustainability: Enhancing carbon capture for sustainable development goals–a review. Sustainable development, 33(2), 2004–2029. https://doi.org/10.1002/sd.3222
- [7] Dhanwe, S. S., Abhangrao, C. M., & Liyakat, K. K. S. (2024). AI-driven IoT in robotics: A review. Journal of mechanical robotics, 9(1), 41–48. https://www.researchgate.net/publication/379654203
- [8] Chan, K. Y., Abu-Salih, B., Qaddoura, R., Al-Zoubi, A. M., Palade, V., Pham, D. S., … ., & Muhammad, K. (2023). Deep neural networks in the cloud: Review, applications, challenges and research directions. Neurocomputing, 545, 126327. https://doi.org/10.1016/j.neucom.2023.126327
- [9] Dai, H., Landry, B., Yang, L., Pavone, M., & Tedrake, R. (2021). Lyapunov-stable neural-network control. https://doi.org/10.48550/arXiv.2109.14152
- [10] Mahmoud, A. T., Mohammed, A. A., Ayman, M., Medhat, W., Selim, S., Zayed, H., … ., & Elaraby, N. (2024). Formal verification of code conversion: A comprehensive survey. Technologies, 12(12), 1–28. https://doi.org/10.3390/technologies12120244
- [11] Li, B., Wen, S., Yan, Z., Wen, G., & Huang, T. (2023). A survey on the control lyapunov function and control barrier function for nonlinear-affine control systems. IEEE/CAA journal of automatica sinica, 10(3), 584–602. https://doi.org/10.1109/JAS.2023.123075
- [12] Wang, C., Qiang, X., Xu, M., & Wu, T. (2022). Recent advances in surrogate modeling methods for uncertainty quantification and propagation. Symmetry, 14(6), 1219. https://doi.org/10.3390/sym14061219
- [13] Reiser, P., Aguilar, J. E., Guthke, A., & Bürkner, P. C. (2025). Uncertainty quantification and propagation in surrogate-based Bayesian inference. Statistics and computing, 35(3), 66. https://doi.org/10.1007/s11222-025-10597-8
- [14] Schöning, J., & Pfisterer, H. J. (2023). Safe and trustful AI for closed-loop control systems. Electronics, 12(16), 1–15. https://doi.org/10.3390/electronics12163489
- [15] Zakka, K., Wu, P., Smith, L., Gileadi, N., Howell, T., Peng, X. Bin, … ., & Zeng, A. (2023). Robopianist: Dexterous piano playing with deep reinforcement learning. https://doi.org/10.48550/arXiv.2304.04150
- [16] Pfanschilling, V., Shindo, H., Dhami, D. S., & Kersting, K. (2025). NeST: The neuro-symbolic transpiler. International journal of approximate reasoning, 179, 109369. https://doi.org/10.1016/j.ijar.2025.109369
- [17] Menghani, G. (2023). Efficient deep learning: A survey on making deep learning models smaller, faster, and better. Association for computing machinery computing surveys, 55(12), 1–37. https://doi.org/10.1145/3578938
- [18] Barron, S. L., Oldroyd, S. V, Saez, J., Chernaik, A., Guo, W., McCaughan, F., … ., & Owens, R. M. (2024). A conformable organic electronic device for monitoring epithelial integrity at the air liquid interface. Advanced materials, 36(8), 2306679. https://doi.org/10.1002/adma.202306679
- [19] Li, P., Rao, X., Blase, J., Zhang, Y., Chu, X., & Zhang, C. (2021). Cleanml: A study for evaluating the impact of data cleaning on ml classification tasks. 2021 IEEE 37th international conference on data engineering (ICDE) (pp. 13–24). IEEE. https://doi.org/10.1109/ICDE51399.2021.00009
- [20] Geelen, R., Balzano, L., & Willcox, K. (2023). Learning latent representations in high-dimensional state spaces using polynomial manifold constructions. 2023 62nd IEEE conference on decision and control (CDC) (pp. 4960–4965). IEEE. https://doi.org/10.1109/CDC49753.2023.10384209
- [21] Bin, M., & Parisini, T. (2023). A small-gain theory for abstract systems on topological spaces. IEEE transactions on automatic control, 68(8), 4494–4507. https://doi.org/10.1109/TAC.2023.3256760
- [22] Luo, J., Xu, C., Wu, J., & Levine, S. (2024). Precise and dexterous robotic manipulation via human-in-the-loop reinforcement learning. https://doi.org/10.48550/arXiv.2410.21845
- [23] Da, L., Turnau, J., Kutralingam, T. P., Velasquez, A., Shakarian, P., & Wei, H. (2025). A survey of sim-to-real methods in RL: Progress, prospects and challenges with foundation models. https://doi.org/10.48550/arXiv.2502.13187
- [24] de Croon, G. C. H. E., Dupeyroux, J. J. G., Fuller, S. B., & Marshall, J. A. R. (2022). Insect-inspired AI for autonomous robots. Science robotics, 7(67), eabl6334. https://doi.org/10.1126/scirobotics.abl6334
- [25] Aleixo, E. L., Colonna, J. G., Cristo, M., & Fernandes, E. (2023). Catastrophic forgetting in deep learning: A comprehensive taxonomy. https://doi.org/10.48550/arXiv.2312.10549
- [26] Zhu, D., Bu, Q., Zhu, Z., Zhang, Y., & Wang, Z. (2024). Advancing autonomy through lifelong learning: A survey of autonomous intelligent systems. Frontiers in neurorobotics, 18, 1385778. https://doi.org/10.3389/fnbot.2024.1385778
- [27] Song, Y. J. X., & Li, J. (2025). MDATA knowledge representation. In MDATA cognitive model: Theory and applications (pp. 24). Springer. https://us.amazon.com/MDATA-Cognitive-Model-Applications-Computer-ebook/dp/B0DN4VSWDL
- [28] Xiang, Q., Zi, L., Cong, X., & Wang, Y. (2023). Concept drift adaptation methods under the deep learning framework: A literature review. Applied sciences, 13(11), 1–27. https://doi.org/10.3390/app13116515
- [29] Mukherjee, A., Divya, A. B., Sivvani, M., & Pal, S. K. (2024). Cognitive intelligence in industrial robots and manufacturing. Computers & industrial engineering, 191, 110106. https://doi.org/10.1016/j.cie.2024.110106
- [30] Malik, I. H. (2024). Can political ecology be decolonised? A dialogue with Paul Robbins. Geo: Geography and environment, 11(1), e00140. https://doi.org/10.1002/geo2.140
- [31] Yan, S., Zhang, B., Zhang, Y., Boedecker, J., & Burgard, W. (2024). Learning continuous control with geometric regularity from robot intrinsic symmetry. 2024 IEEE international conference on robotics and automation (ICRA) (pp. 49–55). IEEE. https://doi.org/10.1109/ICRA57147.2024.10610949
- [32] Wang, X., & Jia, W. (2025). Optimizing edge AI: A comprehensive survey on data, model, and system strategies. https://doi.org/10.48550/arXiv.2501.03265
- [33] Winkle, K., McMillan, D., Arnelid, M., Harrison, K., Balaam, M., Johnson, E., & Leite, I. (2023). Feminist human-robot interaction: Disentangling power, principles and practice for better, more ethical HRI. Proceedings of the 2023 acm/IEEE international conference on human-robot interaction (pp. 72–82). Association for computing machinery. https://doi.org/10.1145/3568162.3576973
- [34] Pilditch, T. D. (2024). The reasoning under uncertainty trap: A structural ai risk. https://doi.org/10.48550/arXiv.2402.01743
- [35] Jonnavittula, A., Mehta, S. A., & Losey, D. P. (2024). SARI: Shared autonomy across repeated interaction. ACM transactions on human-robot interaction, 13(2), 1–36. https://doi.org/10.1145/3651994
- [36] Proia, S. (2024). Control techniques for collaborative and cooperative robotic systems. Politecnico di Bari. https://tesidottorato.depositolegale.it/handle/20.500.14242/64911
- [37] Robinson, N., Tidd, B., Campbell, D., Kulić, D., & Corke, P. (2023). Robotic vision for human-robot interaction and collaboration: A survey and systematic review. Association for computing machinery transactions on human-robot interaction, 12(1), 1–66. https://doi.org/10.1145/3570731
- [38] Soori, M., Arezoo, B., & Dastres, R. (2023). Artificial intelligence, machine learning and deep learning in advanced robotics, a review. Cognitive robotics, 3, 54–70. https://doi.org/10.1016/j.cogr.2023.04.001
- [39] Rahimi, I., Gandomi, A. H., Chen, F., & Mezura-Montes, E. (2023). A review on constraint handling techniques for population-based algorithms: From single-objective to multi-objective optimization. Archives of computational methods in engineering, 30(3), 2181–2209. https://doi.org/10.1007/s11831-022-09859-
- [40] Dawood, M., Pan, S., Dengler, N., Zhou, S., Schoellig, A. P., & Bennewitz, M. (2025). Safe multi-agent reinforcement learning for behavior-based cooperative navigation. IEEE robotics and automation letters, 10(6), 6256-6263. https://doi.org/10.1109/LRA.2025.3560830
- [41] Cao, P., Lei, L., Cai, S., Shen, G., Liu, X., Wang, X., … ., & Guizani, M. (2024). Computational intelligence algorithms for UAV swarm networking and collaboration: A comprehensive survey and future directions. IEEE communications surveys & tutorials, 26(4), 2684–2728. https://doi.org/10.1109/COMST.2024.3395358
- [42] Wan, K., Chen, Y., Zhao, J., & Yu, M. (2022). A decentralized fault-tolerant control for DC microgrids against disturbances and actuator faults. IEEE transactions on smart grid, 14(4), 2534–2544. https://doi.org/10.1109/TSG.2022.3229057
- [43] Pal, S., Dorri, A., & Jurdak, R. (2022). Blockchain for IoT access control: Recent trends and future research directions. Journal of network and computer applications, 203, 103371. https://doi.org/10.1016/j.jnca.2022.103371
- [44] Song, H., & Wang, Z. (2025). Dynamic event-triggered model predictive control for nonlinear discrete cyber-physical systems with hybrid attacks. IEEE transactions on automation science and engineering, 12, 15745–15756. http://dx.doi.org/10.1109/TASE.2025.3572469
- [45] Jain, R., Parmar, K. J., Palaniappan, D., & Premavathi, T. (2025). Hybrid control systems: Integrating AI with traditional methods. In Harnessing AI for control engineering (pp. 37–62). IGI Global Scientific Publishing. http://dx.doi.org/10.4018/979-8-3693-7812-0.ch002
- [46] Abbas, N., Abbas, Z., Zafar, S., Ahmad, N., Liu, X., Khan, S. S., … ., & Larkin, S. (2024). Survey of advanced nonlinear control strategies for UAVs: Integration of sensors and hybrid techniques. Sensors, 24(11), 1–51. https://doi.org/10.3390/s24113286
- [47] Scheres, K. J. A., Postoyan, R., & Heemels, W. M. (2024). Robustifying event-triggered control to measurement noise. Automatica, 159, 111305. https://doi.org/10.1016/j.automatica.2023.111305
- [48] Della Santina, C., Duriez, C., & Rus, D. (2023). Model-based control of soft robots: A survey of the state of the art and open challenges. IEEE control systems magazine, 43(3), 30–65. https://doi.org/10.1109/MCS.2023.3253419
- [49] Nagami, K., & Schwager, M. (2024). State estimation and belief space planning under epistemic uncertainty for learning-based perception systems. IEEE robotics and automation letters, 9(6), 5118–5125. https://doi.org/10.1109/LRA.2024.3387139
- [50] Tan, M., Zhuang, Z., Chen, S., Li, R., Jia, K., Wang, Q., & Li, Y. (2024). EPMF: Efficient perception-aware multi-sensor fusion for 3D semantic segmentation. IEEE transactions on pattern analysis and machine intelligence, 46(12), 8258–8273. https://doi.org/10.1109/TPAMI.2024.3402232
- [51] Sun, R., & Ren, Y. (2024). A multi-source heterogeneous data fusion method for intelligent systems in the Internet of Things. Intelligent systems with applications, 23, 200424. https://doi.org/10.1016/j.iswa.2024.200424
- [52] Shu, F., Wang, J., Pagani, A., & Stricker, D. (2022). Structure plp-slam: Efficient sparse mapping and localization using point, line and plane for monocular, rgb-d and stereo cameras. https://doi.org/10.48550/arXiv.2207.06058
- [53] Wangwongchai, A., Waqas, M., Dechpichai, P., Hlaing, P. T., Ahmad, S., & Humphries, U. W. (2023). Imputation of missing daily rainfall data; A comparison between artificial intelligence and statistical techniques. MethodsX, 11, 102459. https://doi.org/10.1016/j.mex.2023.102459
- [54] Kurniawati, H. (2022). Partially observable markov decision processes and robotics. Annual review of control, robotics, and autonomous systems, 5(1), 253–277. https://doi.org/10.1146/annurev-control-042920-092451
- [55] Taniguchi, A., Tabuchi, Y., Ishikawa, T., El Hafi, L., Hagiwara, Y., & Taniguchi, T. (2023). Active exploration based on information gain by particle filter for efficient spatial concept formation. Advanced robotics, 37(13), 840–870. https://doi.org/10.1080/01691864.2023.2225175
- [56] Bélisle-Pipon, J. C., Monteferrante, E., Roy, M. C., & Couture, V. (2023). Artificial intelligence ethics has a black box problem. AI & society, 38, 1507–1522. https://doi.org/10.1007/s00146-021-01380-0
- [57] Zeraati, M., Sheibani, M. R., Jabari, F., & Heydarian-Forushani, E. (2024). A novel state estimation method for distribution networks with low observability based on linear AC optimal power flow model. Electric power systems research, 228, 110085. https://doi.org/10.1016/j.epsr.2023.110085
- [58] Cifci, A. (2025). Interpretable prediction of a decentralized smart grid based on machine learning and explainable artificial intelligence. IEEE access, 13, 36285–36305. https://doi.org/10.1109/ACCESS.2025.3543759
- [59] Dubey, S. R., Singh, S. K., & Chaudhuri, B. B. (2022). Activation functions in deep learning: a comprehensive survey and benchmark. Neurocomputing, 503, 92–108. https://doi.org/10.1016/j.neucom.2022.06.111
- [60] Kuznetsov, S. D., Velikhov, P. E., & Fu, Q. (2023). Real-time analytics: Benefits, limitations, and tradeoffs. Programming and computer software, 49(1), 1–25. https://doi.org/10.1134/S036176882301005X
- [61] Gupta, S. (2025). AI agents collaboration under resource constraints: Practical implementations. International journal of artificial intelligence research and development, 3(1), 51–63. http://dx.doi.org/10.34218/IJAIRD_03_01_004
- [62] Alhussain, A. (2024). Efficient processing of convolutional neural networks on the edge: A hybrid approach using hardware acceleration and dual-teacher compression. https://stars.library.ucf.edu/etd2023/321/
- [63] Flamm, B., Peter, C., Büchi, F. N., & Lygeros, J. (2021). Electrolyzer modeling and real-time control for optimized production of hydrogen gas. Applied energy, 281, 116031. https://doi.org/10.1016/j.apenergy.2020.116031
- [64] Zhao, Z., Cheng, S., Ding, Y., Zhou, Z., Zhang, S., Xu, D., & Zhao, Y. (2024). A survey of optimization-based task and motion planning: From classical to learning approaches. IEEE/ASME Transactions On Mechatronics, 1-
- [27] https://doi.org/10.1109/TMECH.2024.3452509
- [65] Chacko, K., Augustine, M. T., Janardhanan, S., Patil, D. U., & Kar, I. N. (2023). Approximate dynamic programming based model predictive control of nonlinear systems. https://doi.org/10.48550/arXiv.2312.05952
- [66] Sharony, E., Yang, H., Che, T., Pavone, M., Mannor, S., & Karkus, P. (2024). Learning multiple initial solutions to optimization problems. https://doi.org/10.48550/arXiv.2411.02158